notes from the build
signals
What we learn bringing robots into real rooms with real people.
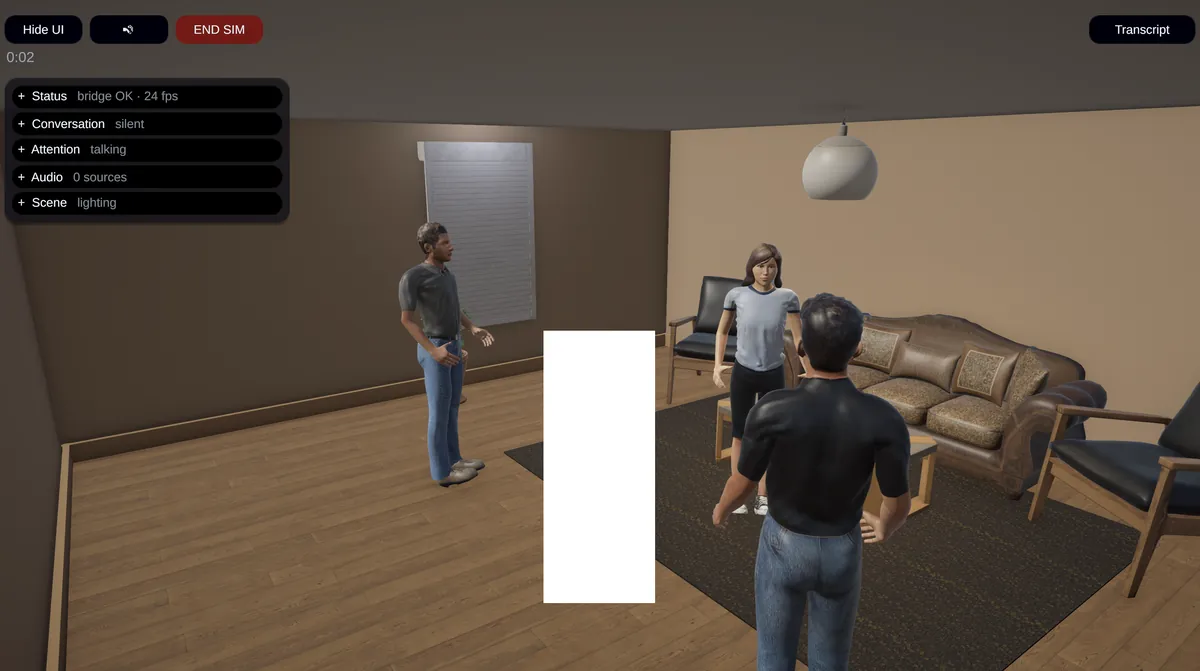
Auto Evaluation for Real2Sim2Real
Building a local robot-evaluation workshop on NVIDIA DGX Spark™: several open models look at each real-world recording eight times, a human checks the result, and the labels feed our simulator.
read →